

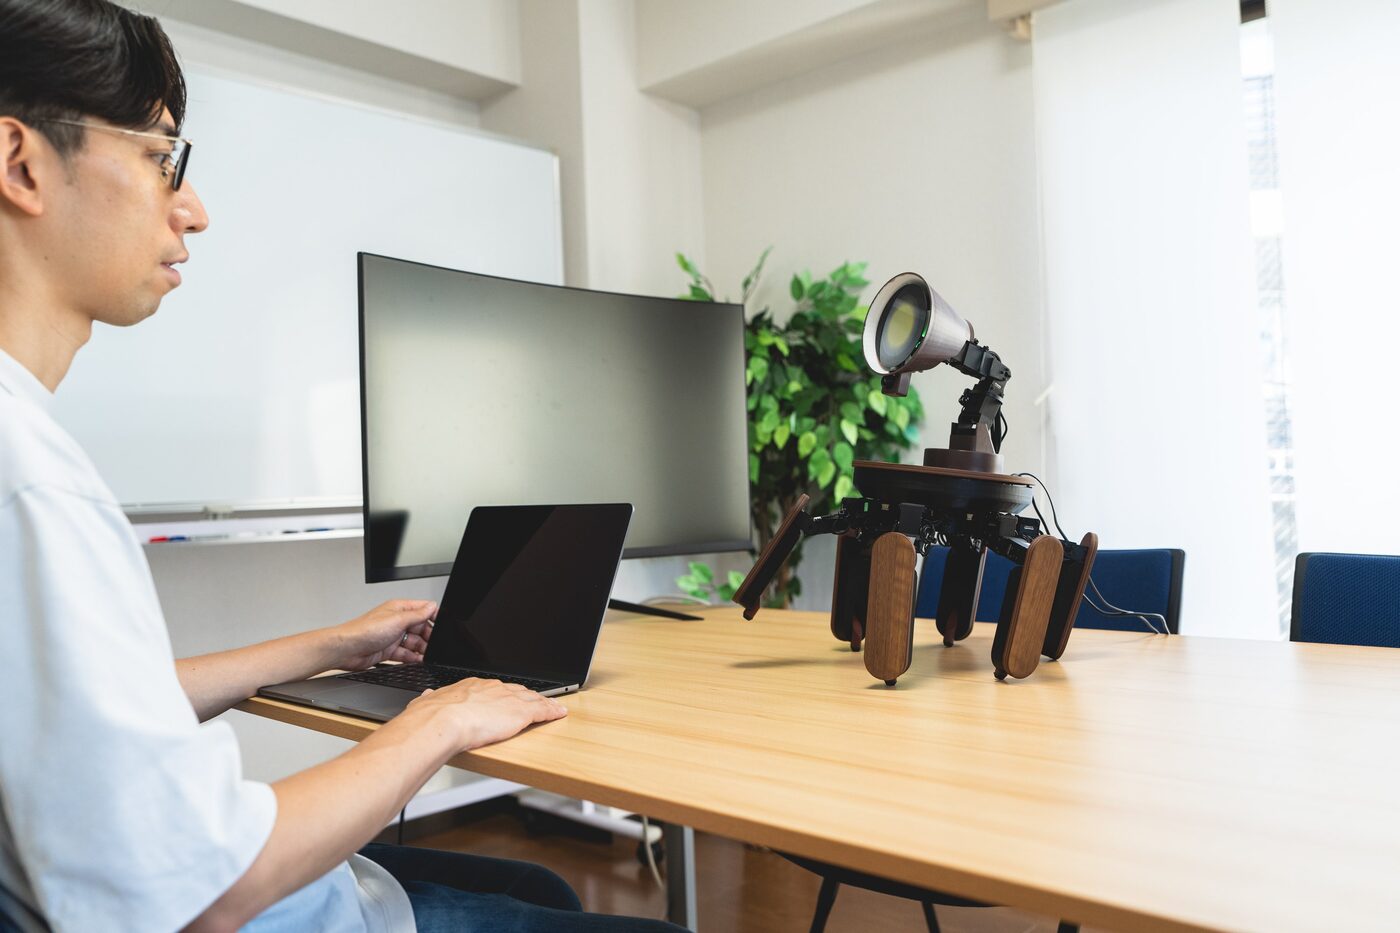
Palmimo DevKit gives AI agents a body: a customizable, general-purpose AI robot you drive with your own code, shipped assembled and tested. Palmimo itself is a six-legged desktop companion robot: 18 leg servos walk it around on a tripod gait, a servo neck aims a round face display, and a small expression engine gives it a face. It also has a camera, a microphone and a speaker, and the SDK hands each of them to the robot the same way — which is why the robot below changes its face, shows you what it sees, and records when you ask it to.
mic
The 3D model needs JavaScript. The photograph above shows the same robot.
Drag to turn it over, scroll to zoom. The Python prompt drives this robot: what you run there, it does here.
idle
from palmimo_sdk import NeckYawDegrees, Palmimo
from stage_bridge import StageCamera, StageDisplay, StageMic
robot = Palmimo(camera=StageCamera(), display=StageDisplay(), mic=StageMic())
robot.connect()
# Already run -- the real palmimo_sdk, with this page standing in for the camera, display and mic.
A single motion engine (pure gait and inverse kinematics, no I/O) drives
the robot through interchangeable front-ends — the palmimo_sdk Python API
and example agent apps — and every motion computes in dry-run, with no
hardware attached, before it ever reaches a servo.
Tripod A and tripod B, in anti-phase: three legs carry while three swing.
Make it move
Section titled “Make it move”No robot yet? Every motion computes without hardware, so start anywhere.